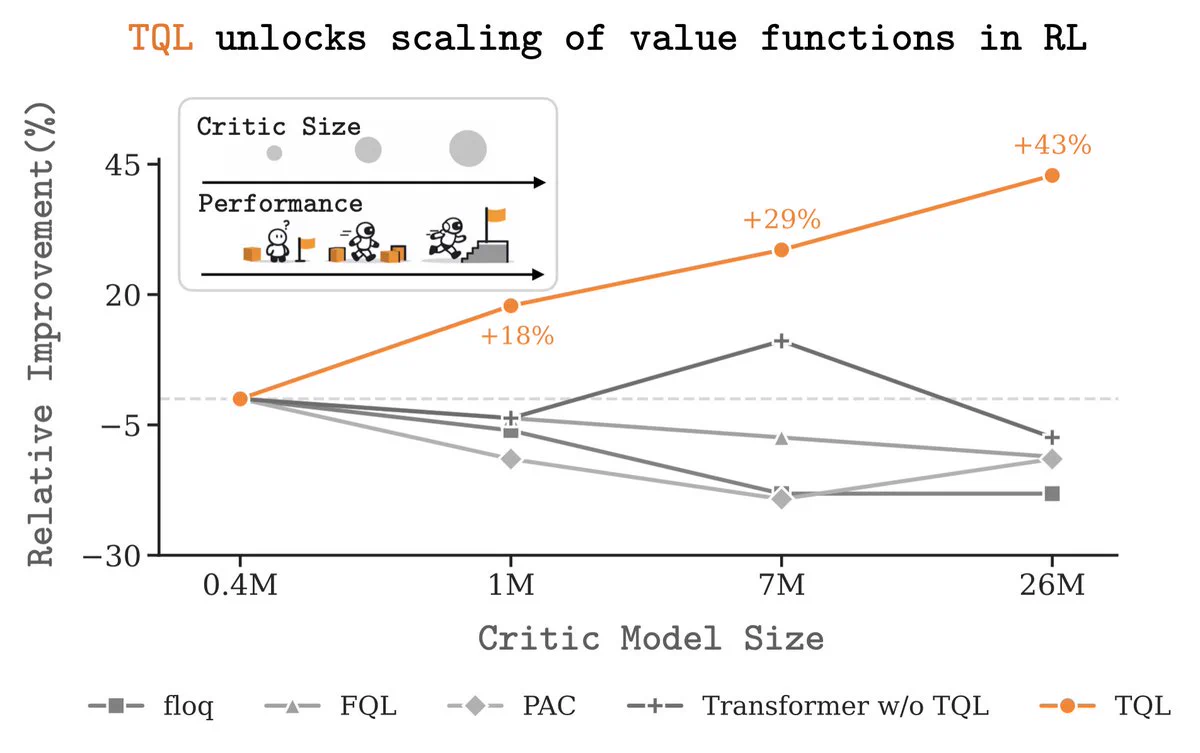
In language models, turning a generative model into a critic is simple: pass in the output and prompt for a score. Robot policies can't do this - they output physical actions & there's no built-in vocabulary to predict scores.
So when it comes to RL on robot policies, we