Innovation in (Soft) Robotics and Control - Spring 2025
Robotics, Vision, and Controls Talks Spring 2025
February - May 2025
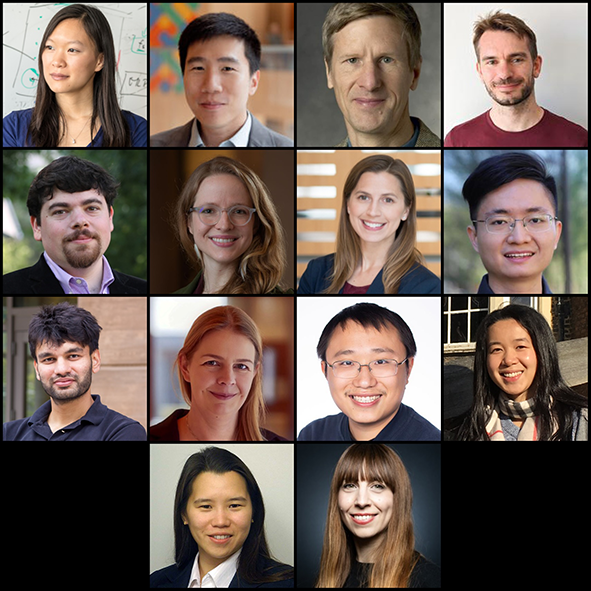
This semester featured 15 outstanding talks focusing on soft robotics, foundation models, humanoid control, and bio-inspired systems. All talks are available as recordings.
Featured Talks
Prof. Dr. Perla Maiolino - University of Oxford
“Soft and Perceptive Robots” • May 28, 2025 Watch Recording
For decades, robotics has been defined by the need to avoid physical contact for safety, leading to rigid machines that interact with their environment in a limited way. However, true intelligence emerges from physical interaction between the environment and an agent’s own body, through which an awareness of both the external environment and the Self is built.
More details
In this talk, we explore how soft robotics and tactile sensing are transforming robotic intelligence by making physical interaction a fundamental part of perception. By designing robots with compliant, adaptable bodies and highly integrated sensor technologies, we enable them to perceive the world through touch, much like biological organisms. **Speaker Bio:** Perla Maiolino is an Associate Professor at the Engineering Science Department and a member of Oxford Robotic Institute, University of Oxford, where she has established the ORI Soft Robotics Laboratory. Her research interests are related to the development of new technological solutions for soft robot sensors and actuators.Prof. Dr. Cynthia Sung - University of Pennsylvania
“Salp-Inspired Approach to Underwater Multi-Robot Locomotion” • May 23, 2025 Watch Recording
Soft robots introduce new opportunities for design and control approaches that take advantage of a robot’s internal mechanics to perform a task. We are inspired by the biological salp, an underwater jelly that grows in colonies, and how salp colonies can produce higher speed, agility, or cost of transport than a single unit.
Prof. Dr. Keenan Albee - JPL / USC
“Autonomy On-Orbit and Beyond: Expanding Mission Capabilities in Extreme Environment Robotics” • May 22, 2025
Watch Recording
Autonomy is essential to making rapid decisions in safety-critical situations and dealing with tasks too complex for a human teleoperator. This talk explores algorithmic and safety challenges of working with increasing complexity in space and extreme environment robotics autonomy.
Prof. Dr. Hilde Kuehne - Tuebingen AI Center and MIT-IBM Watson AI Lab
“Advances in self-supervised multimodal learning” • May 21, 2025 Watch Recording
The field of multimodal learning has witnessed significant progress in recent years, mainly enabled by advances in contrastive and autoregressive learning techniques. This talk presents the latest developments focusing on embedding space learning and vision-language models.
Prof. Dr. Lingjie Liu - University of Pennsylvania
“Towards Next-Gen 3D Reconstruction and Generation: From Visual Fidelity to Multimodal and Physical Understanding” • May 14, 2025 Watch Recording
Recent years have witnessed remarkable progress in 3D reconstruction and generation. However, most existing methods primarily focus on modeling geometry and appearance. The next generation should go further in two key directions: multimodal alignment and physical understanding.
Prof. Dr. Xiaolong Wang - UC San Diego
“Modeling Humans for Humanoid Robots” • May 9, 2025 Watch Recording
Having a humanoid robot operating like a human has been a long-standing goal in robotics. This talk presents a 2-level learning framework designed to equip humanoid robots with robust mobility and manipulation skills, enabling them to generalize across diverse tasks, objects, and environments.
Prof. Dr. Pulkit Agrawal - MIT
“Pathway to Robotic Intelligence” • April 16, 2025 Watch Recording
This talk presents recent works that aim to achieve both generalist-level adaptability and specialist-level agility, demonstrated across various real-world robots, including full-size humanoids, quadrupeds, aerial robots, and ground vehicles.
Prof. Dr. Guanya Shi - CMU
“Building Generalist Robots with Agility via Learning and Control: Humanoids and Beyond” • April 11, 2025 Watch Recording
Recent advances in AI and robotics have brought us closer to building general-purpose robots. Two key challenges are achieving “breadth” in task/environment diversity and “depth” in task execution.
Prof. Dr. Kristen Grauman - UT Austin
“Video understanding for skill learning” • April 2, 2025
Watch Recording
The first-person or “egocentric” perspective offers a special window into an agent’s attention, goals, and interactions, making it an exciting avenue for the future of both augmented reality and robot learning.
Prof. Dr. Kaitlyn Becker - MIT
“Desktop to Deep Sea: Mechanical Programming of Soft Machines” • March 28, 2025 Watch Recording
As a relatively nascent field, soft robotics can leverage design, modeling, and manufacturing frameworks from traditional machine design. This talk shows how details of material choice, structural design, and manufacturing come together to mechanically program soft machines.
Prof. Dr. Jeffrey Lipton - Northeastern / BG
“Robots With a Twist” • March 19, 2025 Watch Recording
Robot bodies’ abilities depend on the materials they are made from. This talk shows how to bridge traditional and soft robotics using metamaterials that respond to torque, improving how robots can grasp, walk and interact with people.
Dr. Oier Mees - UC Berkeley
“Embodied Multimodal Intelligence with Foundation Models” • March 14, 2025 Watch Recording
Despite considerable progress in robot learning, most real-world robots remain confined to a narrow set of preprogrammed behaviors. This talk discusses building robot foundation models capable of performing diverse tasks across different embodiments.
Prof. Dr. Mark R. Cutkosky - Stanford University
“ReachBot: Locomotion and Manipulation with Exceptional Reach” • March 5, 2025
Watch Recording
ReachBot is a joint project between Stanford and NASA to explore a new approach to mobility in challenging environments such as martian caves. It consists of a compact robot body with very long extending arms based on extendable antenna booms.
Prof. Dr. Kevin Chen - MIT
“Insect-scale aerial robots driven by soft artificial muscles” • February 28, 2025 Watch Recording
Flapping-wing flight at the insect-scale is incredibly challenging. This work demonstrates the first heavier-than-air aerial robot powered by soft artificial muscles, achieving 1000-second hovering flight and collision recovery capabilities.
Prof. Dr. Angela Dai - TU Munich
“From Quantity to Quality for 3D Perception” • February 19, 2025
Watch Recording
Recent advances in machine learning have shown remarkable progress in 2D and video domains, but 3D remains constrained by limited data. This talk explores combining 3D learning with multi-modal priors from text and images.
Semester Statistics
- Total Talks: 15
- Institutions Represented: 12
- Countries: 3 (US, UK, Germany)
| ← Back to Archives | Current Talks |
