NEW! ICRA Paper Title Generator!
(no GPTs were harmed in the making of the above title)
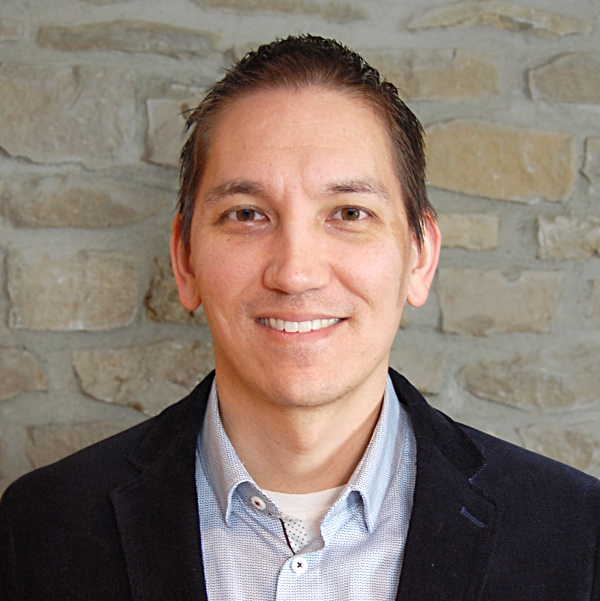
Head of Robotic Intelligence
Samsung Research America
Professor
Department of Computer Science
Department of Electrical and Computer Engineering
Department of Mechanical Science and Engineering
Director, Coordinated Sciences Lab Robotics Group
University of Illinois at Urbana-Champaign
Bio
Kris Hauser is a Professor in the Siebel School of Computing and Data Science at the University of Illinois at Urbana-Champaign, and Affiliate of the Department of Electrical and Computer Engineering and the Department of Mechanical Science and Engineering. He received his PhD in Computer Science from Stanford University in 2008, bachelor's degrees in Computer Science and Mathematics from UC Berkeley in 2003, and worked as a postdoctoral fellow at UC Berkeley. He then joined the faculty at Indiana University from 2009-2014, where he started the Intelligent Motion Lab, and then joined the faculty of Duke University from 2014-2019. He also has consulted for Google's autonomous driving company, Waymo, from 2019-2023. Prof. Hauser is a recipient of a Stanford Graduate Fellowship, Siebel Scholar Fellowship, Best Paper Award at IEEE International Conference on Humanoid Robots 2015, the NSF CAREER award, and three Amazon Research Awards. He is currently on leave from UIUC, serving as Head of Robotic Intelligence at Samsung Research America.
Research
Research interests include open-world robotics, robot motion planning and control, and semi-autonomous systems, with applications to intelligent vehicles, robotic manipulation, robot-assisted medicine, and legged locomotion.
More information can be found on the Intelligent Motion Lab website...
Selected Publications

 Supplemental video
 Supplemental video

Also in ICRA 2024 4th Workshop on Representing and Manipulating Deformable Objects, May 17, 2024.
- R. Moan, C. McBeth, M. Morales, N. Amato, and K. Hauser. Experience-Based Multi-Agent Path Finding with Narrow Corridors. Robotics: Science and Systems (RSS), July 2024.
- J. M. C. Marques, A. Zhai, S. Wang, Kris Hauser. On the Overconfidence Problem in Semantic 3D Mapping. IEEE International Conference on Robotics and Automation, 2024.
 Supplemental video
- P. Naughton, J. S. Nam, A. Stratton and K. Hauser. Integrating Open-World Shared Control in Immersive Avatars. IEEE International Conference on Robotics and Automation, 2024. Also in Arxiv, January 5, 2024.
Supplemental video
- K. Hauser, E. Watson, J. Bae, J. Bankston, S. Behnke, B. Borgia, M. Catalano, S. Dafarra, J.B.F. van Erp, T. Ferris, J. Fishel, G. Hoffman, S. Ivaldi, F. Kanehiro, A. Kheddar, G. Lannuzel, J.F. Morie, P. Naughton, S. NGuyen, P. Oh, T. Padir, J. Pippine, J. Park, D. Pucci, J. Vaz, P. Whitney, P. Wu, and D Locke. Analysis and Perspectives on the ANA Avatar XPRIZE Competition. International Journal on Social Robotics, January 30, 2024. doi:10.1007/s12369-023-01095-w
- Y. Zhu, P. Thangeda, M. Ornik, and K. Hauser. Few-shot Adaptation for Manipulating Granular Materials Under Domain Shift. Robotics: Science and Systems (RSS), July 2023.
- M. Zhang, D. Jha, A. Raghunathan, and K. Hauser. Simultaneous Trajectory Optimization and Contact Selection for Multi-Modal Manipulation Planning. Robotics: Science and Systems (RSS), July 2023.
- S. Yao and K. Hauser. Estimating Tactile Models of Heterogeneous Deformable Objects in Real Time. IEEE International Conference on Robotics and Automation (ICRA), May 2023.
- Z. Pan, A. Zheng, Y. Li, J. Yu, and K. Hauser. Algorithms and Systems for Manipulating Multiple Objects. IEEE Transactions on Robotics, 39(1):2-20, 2023.
- Y. Zhou and K. Hauser. CPI: Conservativeness, Permissiveness and Intervention Metrics for Shared Control Evaluation. IEEE Robotics and Automation Letters, 7(3):6367-6374, July 2022. doi: 10.1109/LRA.2022.3169581
- M. Zhang and K. Hauser. Non-Penetration Iterative Closest Points for Single-View Multi-Object 6D Pose Estimation. IEEE International Conference on Robotics and Automation (ICRA), May 2022.
- Y. Zhu, A. Smith, and K. Hauser. Automated Heart and Lung Auscultation in Robotic Physical Examinations. IEEE Robotics and Automation Letters, 7(2):4204-4211, April 2022. doi: 10.1109/LRA.2022.3149576
- P. Naughton and K. Hauser. Structured Action Prediction for Teleoperation in Open Worlds. IEEE Robotics and Automation Letters, 7(2):3099-3105, April 2022. doi: 10.1109/LRA.2022.3145953.
Supplemental video
- W. Edwards, G. Tang, Y. Tian, M. Draelos, J. Izatt, A. Kuo, and K. Hauser. Data-driven Modelling and Control for Robot Needle Insertion in Deep Anterior Lamellar Keratoplasty. IEEE Robotics and Automation Letters, 7(2):1526-1533, April 2022. doi: 10.1109/LRA.2022.3140458.
- F. Wang and K. Hauser. Dense Robot Packing of Irregular and Novel 3D Objects. IEEE Transactions on Robotics, 2021. doi:10.1109/TRO.2021.3097261.
- W. Sun, G. Tang, and K. Hauser. Fast UAV Trajectory Optimization using Bilevel Optimization with Analytical Gradients. IEEE Transactions on Robotics, 37(6):2010-2024, Dec, 2021. doi:10.1109/TRO.2021.3076454.
- M. Draelos, P. Ortiz, R. Qian, B. Keller, K. Hauser, A. Kuo, and J. Izatt. Robotic Optical Coherence Tomography Scanner for Contactless Autonomous Eye Imaging of Freestanding Subjects. Nature Transactions on Biomedical Engineering, 5(7), 726-736, 2021. doi:10.1038/s41551-021-00753-6.
- J. M. C. Marques, R. Ramalingam, Z. Pan, and K. Hauser. Optimized Coverage Planning for UV Surface Disinfection. IEEE International Conference on Robotics and Automation (ICRA), May 2021.
- W. Edwards, G. Tang, G. Mamakoukas, T. Murphey, and K. Hauser. Automatic Tuning for Data-driven Model Predictive Control. IEEE International Conference on Robotics and Automation (ICRA), May 2021.
Errata - K. Hauser. Semi-Infinite Programming for Trajectory Optimization with Nonconvex Obstacles. International Journal of Robotics Research, Jan. 10, 2021. doi:10.1177/0278364920983353
- F. Wang and K. Hauser. Robot Packing with Known Items and Nondeterministic Arrival Order. IEEE Transactions on Automation Science and Engineering, 2020.
- Y. Zhu, K. Lu, and K. Hauser. Semi-Empirical Simulation of Learned Force Response Models for Heterogeneous Elastic Objects. IEEE International Conference on Robotics and Automation (ICRA), June 2020 Summary video ICRA 10-minute talk video
- M. Draelos, G. Tang, B. Keller, A. Kuo, K. Hauser, J. A. Izatt. Optical Coherence Tomography Guided Robotic Needle Insertion for Deep Anterior Lamellar Keratoplasty. IEEE Transactions on Biomedical Engineering, Nov. 20, 2019. doi:10.1109/TBME.2019.2954505
- G. Tang, W. Sun, and K. Hauser. Time-Optimal Trajectory Generation for Dynamic Vehicles: A Bilevel Optimization Approach. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), October, 2019.
- F. Wang and K. Hauser. Stable Bin Packing of Non-convex 3D Objects with a Robot Manipulator. IEEE International Conference on Robotics and Automation, May, 2019. (A prior version was available in ArXiv, 2018.)
- Y. Zhu, L. Abdulmajeid, and K. Hauser. Data-driven Approach for Fast Simulation of Robot Locomotion on Granular Media. IEEE International Conference on Robotics and Automation, May, 2019. ICRA video
- K. Hauser and Y. Zhou. Asymptotically Optimal Planning by Feasible Kinodynamic Planning in State-Cost Space. IEEE Transactions of Robotics, 32(6): 1431-1443, 2016. Also in arXiv:1505.04098 [cs.RO], 2015.
- K. Hauser. The Minimum Constraint Removal Problem with Three Robotics Applications. International Journal of Robotics Research, 33(1):5-17, January, 2014. doi: 10.1177/0278364913507795
Information for Prospective Students
I am on leave from UIUC, so I will not be accepting new students for now. Please consider approaching the other great robotics faculty and AI faculty at UIUC.Information for Reviewers
Reviewers are the unsung heroes of the academic enterprise. Although I would prefer that reviewers be fairly compensated by journals and conferences, that doesn't seem like it will happen any time soon. As a small consolation, my standing policy is that if you perform a review for me, I will happily treat you to to a drink or lunch as a token of thanks for your service. Meet me in person (e.g., at a conference) to redeem this offer!
Blog posts and other musings
- Putting the Systems Back into RSS: Recommendations for Reviewers and Authors (8/23/2023)
- Toward open world robotics (8/6/2022)
- An open letter from the Program Chair of Robotics: Science and Systems 2022 (9/30/2021)
- Why I don't teach ROS to robotics students (1/31/2021)
- Should society regulate the irrationality of human nature? (2/22/2019)
- The 10 biggest technical hurdles in robotics (4/27/2017)
- A Convergence Result for the Baby Feeding Problem (1/19/2009). (incomplete; I'll have to finish this at some point!)
Prof. Hauser is an avowed atheist, humanist, and socialist. He is a member of the Freedom From Religion Foundation and The Satanic Temple. In his free time he enjoys rock climbing, skiing, diving, and spending quality time with his family and their two Great Danes.
Teaching
- Fall 2024. CS 598KKH: Advanced Computational Topics in Robotics, UIUC
- Spring 2024. CS 588: Autonomous Vehicle Systems Engineering, UIUC
- Fall 2023. CS 598KKH: Advanced Computational Topics in Robotics, UIUC
- Fall 2022. CS 598KKH: Advanced Computational Topics in Robotics, UIUC
- Spring 2022. CS 498IR: AI for Robot Manipulation, UIUC
- Fall 2021. CS 598KKH: Advanced Computational Topics in Robotics, UIUC
- Spring 2021. CS 498IR: AI for Robot Manipulation, UIUC
- Spring 2020. CS 498IR: Intelligent Robotics, UIUC
- Spring 2019. ECE 489/MEMS 555.06: Advanced Robotic System Design, Duke University
- Fall 2018. ECE 383/MEMS 442/MEMS 555: Introduction to Robotics and Automation, Duke University
- Spring 2018. ECE 590: Motion Planning and Optimal Control, Duke University
- Fall 2017. ECE 383 / MEMS 442: Intro to Robotics and Automation
- Spring 2017. CS 270: Introduction to Artificial Intelligence, Duke University; ECE 590: Amazon Robotics Challenge, Duke University
- Fall 2016. ECE 383 / MEMS 442: Intro to Robotics and Automation
- Spring 2016. ECE 490 / MEMS 555: Advanced Robot System Design
- Fall 2015. ECE 383 / MEMS 442: Intro to Robotics and Automation
- Spring 2015. ECE 590: Intelligent Robot Motion
- Spring 2014. I400/I590/B659: Intelligent Robots
- Fall 2013. B351 Introduction to Artificial Intelligence and Computer Simulation
- Spring 2012. B553 Optimization and Learning Algorithms
Notes
My lab and I maintain the Klamp't package for robot modeling, planning, visualization, simulation, and control. Most people pip install klampt and find it useful for kinematics, geometry manipulation, and visualization.
More information is available in the manual and tutorials (C++, Python).
